Menu

Dexterous Robotic Hands

Free framework reorients over 2,000 diverse objects with a hand facing both upward and downward, in a step toward more human-like manipulation in research using MGHPCC computing resources.

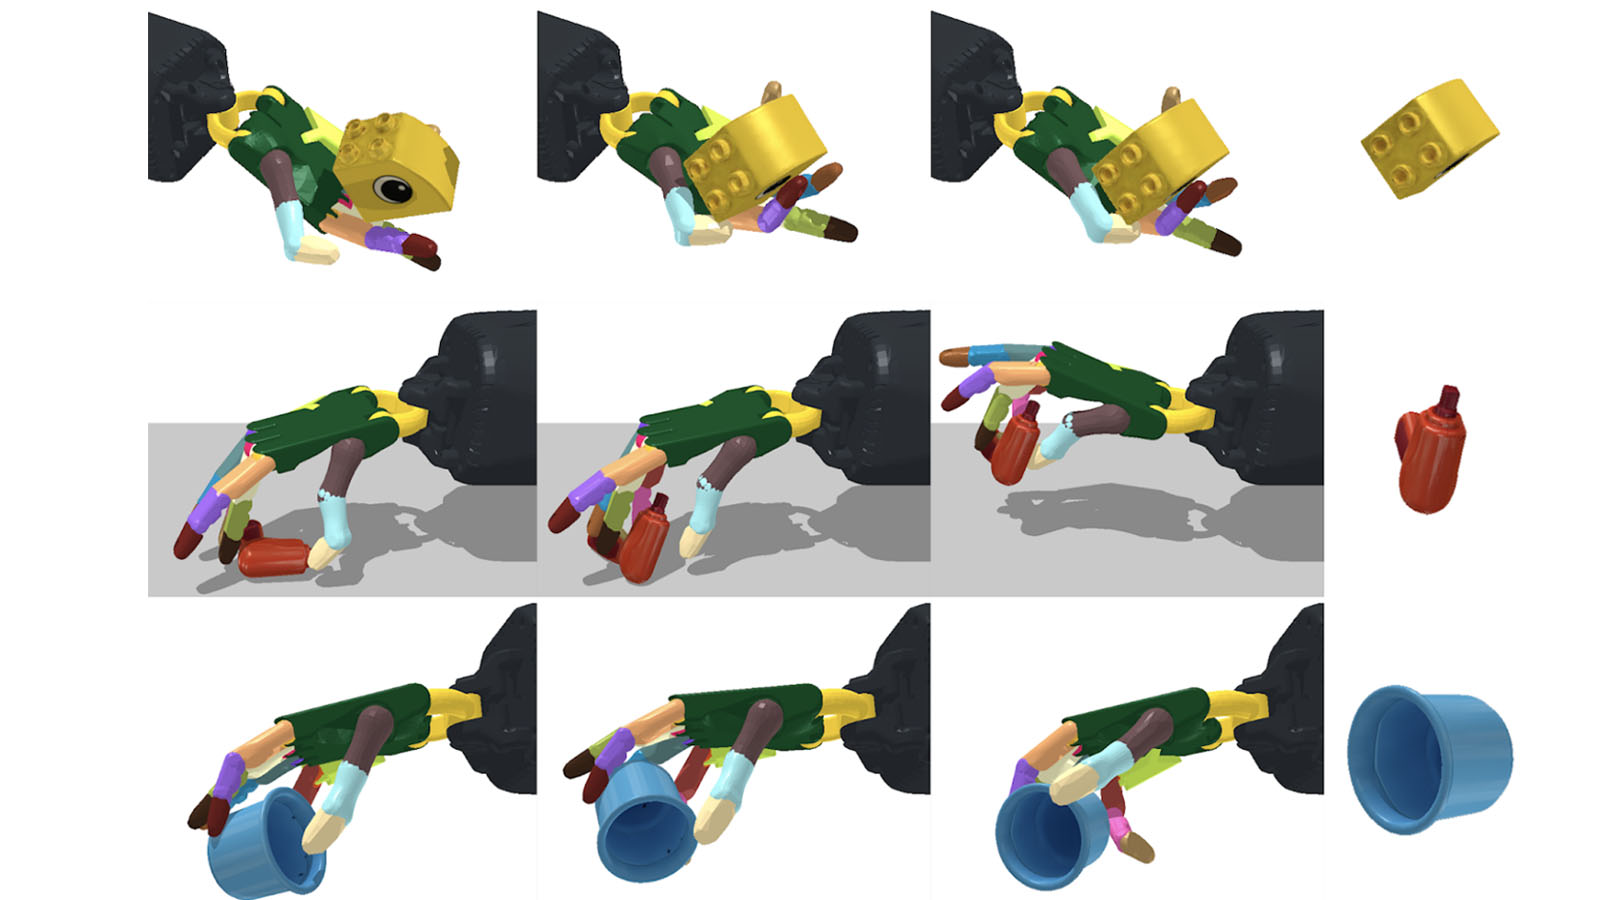
At one year old, a baby is more dexterous than a robot. While machines can perform tasks, they lack natural exploratory and sophisticated manipulation skills. OpenAI’s Dactyl uses a humanoid robot hand to solve a Rubik’s cube, moving towards general AI. DeepMind’s RGB-Stacking system teaches robots to grab and stack items. MIT’s CSAIL developed a framework enabling a robotic hand to reorient over 2,000 objects, enhancing its ability to manipulate various items and generalize to unseen objects. This progress aims to replicate human dexterity in machines.

Pulkit Agrawal
Assistant Professor in the Department of Electrical Engineering and Computer Science (EECS) at MIT

Research projects

Surface Behavior
Social Capital and Economic Mobility
Naval and Ocean Renewable Energy Hydrodynamics
Ephemeral Stream Water Contributions to US Drainage Networks
Developing Advanced Materials for a Sustainable Energy Future
The Kempner Institute - Unlocking Intelligence
Asteroid Data Mining
Pulling Back the Quantum Curtain on ‘Weyl Fermions’
All Research Projects

Collaborative projects

ALL Collaborative PROJECTS

OUTREACH & EDUCATION PROJECTS

See ALL Scholarships
100 Bigelow Street, Holyoke, MA 01040